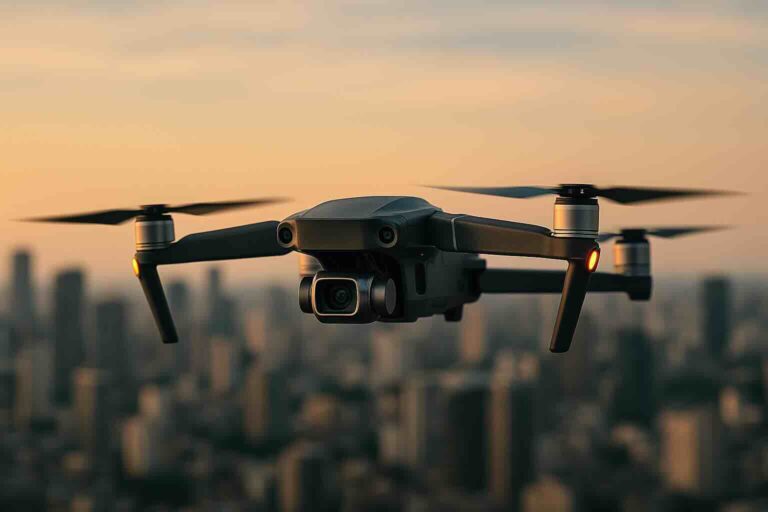
Thinking about starting drone programming as a developer in 2026? This guide walks you through the core concepts, tools, languages, and steps to build your first drone project — updated for how the field actually looks today, including the shift toward AI-powered autonomy that’s reshaping what “programming a drone” even means.
Table of Contents
- Introduction to Drone Programming
- Why Developers Should Explore Drones in 2026
- How Drones Work: Basic Components
- Core Programming Concepts for Drones
- Popular Drone Platforms and SDKs
- Best Programming Languages for Drone Development
- AI and Autonomy: What’s Actually New in 2026
- Setting Up Your Drone Development Environment
- Writing Your First Drone Script
- Drone Simulators for Testing Code
- Key Challenges and Safety Tips
- Resources and Learning Roadmap
- Frequently Asked Questions
- Final Thoughts
1. Introduction to Drone Programming
Drones have moved well past hobbyist toys — they’re now core infrastructure in agriculture, construction, logistics, filmmaking, and public safety. For developers, drone programming sits at a genuinely rare intersection: real-time embedded systems, computer vision, robotics, and — increasingly — AI decision-making, all running on hardware that has to survive actual physics.
If you’ve already built web or mobile apps and you’re curious about controlling something that flies, this guide is your on-ramp. We’ll cover the fundamentals with an emphasis on tools and workflows you can actually start using this week.
2. Why Developers Should Explore Drones in 2026
- AI-native opportunity: Drone platforms are increasingly shipping with onboard AI companion computers, meaning “drone programming” now overlaps directly with computer vision and edge AI work — skills already in high demand.
- Expanding industries: Delivery, precision agriculture, infrastructure inspection, and security are scaling up commercial drone deployments, not just piloting them manually.
- Cross-disciplinary skill-building: Combines embedded systems, robotics, IoT, and AI — a genuinely differentiated skill set on a resume.
- Active open-source ecosystem: Projects like PX4 and Dronecode continue shipping regular releases with real contributor activity, meaning documentation, community support, and job-relevant tooling keep improving.
3. How Drones Work: Basic Components
Before writing any code, it helps to know what you’re actually programming:
- Flight Controller — the drone’s “brain,” a microcontroller running the flight stack (e.g., PX4 or ArduPilot).
- ESCs (Electronic Speed Controllers) — regulate motor speed based on flight controller commands.
- Motors & Propellers — generate thrust and lift.
- GPS Module — enables location-based navigation and waypoint missions.
- IMU (Inertial Measurement Unit) — gyroscope + accelerometer, tracks orientation and motion.
- Companion Computer (increasingly standard in 2026) — a small onboard computer (like a Raspberry Pi or NVIDIA Jetson board) that runs heavier compute — object detection, path planning, AI inference — separate from the real-time flight controller.
- Camera / Sensors — for FPV, computer vision, obstacle detection, or LiDAR-based mapping.
- Battery — power source; battery management is a real programming concern, not just hardware.
4. Core Programming Concepts for Drones
- Waypoint Navigation — sending the drone to specific GPS coordinates in sequence.
- Sensor Data Collection — reading and interpreting altitude, GPS, IMU, and camera data in real time.
- PID Control Loops — the classic feedback-loop math that keeps a drone stable in flight.
- Autonomous Behavior — scripting take-off, landing, obstacle avoidance, and return-to-home logic.
- Communication Protocols — MAVLink is the dominant standard for drone-to-ground and drone-to-companion-computer communication; UART and I2C handle onboard sensor communication.
- State Machines — structuring flight logic (idle → armed → flying → returning → landed) is one of the most common real-world patterns you’ll write.
5. Popular Drone Platforms and SDKs
- DJI SDKs (Mobile, Onboard, Payload, Cloud API) — DJI maintains a genuinely active developer ecosystem, with the Mobile SDK, Payload SDK, and Cloud API all receiving regular updates supporting current enterprise drone lines (Matrice, Mavic Enterprise series). Best if you’re building on DJI hardware specifically.
- PX4 Autopilot — open-source flight stack, still one of the most active projects in the space, with steady point releases adding features like improved sensor drivers and control/estimation refinements. Works with QGroundControl and MAVSDK.
- ArduPilot — the other major open-source flight stack, highly customizable, strong community support, supports an enormous range of vehicle types beyond just multirotors (planes, rovers, submarines).
- MAVSDK — modern Python, C++, and Java/Swift APIs for talking to any MAVLink-compatible drone. This is usually the fastest path from “I know how to code” to “my drone just did something.”
- Dronecode Foundation projects — the umbrella organization behind PX4 and MAVSDK; a good place to track the health and direction of the open-source drone ecosystem.
- ROS 2 (Robot Operating System) — increasingly the backbone for anyone doing serious autonomy or multi-sensor fusion work; PX4’s ecosystem has been investing in tighter ROS 2 integration, including tooling for message handling across versions.
6. Best Programming Languages for Drone Development
- Python — still the best starting point. Clean syntax, fast prototyping, first-class support in MAVSDK and DroneKit.
- C++ — required for real-time, performance-critical flight firmware work (PX4 and ArduPilot are both C++ at the core).
- Rust — steadily gaining real traction in the drone/robotics space for performance-critical components where memory safety matters — worth learning if you’re heading toward firmware-level work.
- JavaScript/TypeScript — for browser-based ground control dashboards and telemetry visualization.
- Java/Kotlin/Swift — for native mobile ground-control apps (DJI Mobile SDK supports these directly).
7. AI and Autonomy: What’s Actually New in 2026
This is the section that didn’t really exist in most beginner guides even a year or two ago — and it’s arguably the most important shift in the field right now.
- Onboard AI inference is becoming standard, not exotic — companion computers running lightweight models for real-time object detection, tracking, and obstacle avoidance, rather than sending video back to a human pilot for every decision.
- Computer vision for autonomous navigation — models trained for obstacle detection (commonly YOLO-family architectures) now run directly on companion computers, letting drones make split-second avoidance decisions without a network round-trip.
- Agentic, task-level autonomy — instead of scripting a fixed waypoint mission, developers are increasingly building drones that receive a high-level goal (“inspect this field and flag anomalies”) and plan the specific flight path and data-collection steps themselves. This mirrors the broader shift toward agentic AI happening across the software industry, applied to physical, moving systems.
- What this means for beginners: you don’t need to master AI/ML before starting drone programming — but it’s worth knowing early that “drone programmer” and “computer vision engineer” are converging roles, and investing time in basic computer vision concepts (even just OpenCV) pays off fast once you’re past the fundamentals in this guide.
8. Setting Up Your Drone Development Environment
Hardware you’ll want:
- A laptop with at least 8GB RAM (16GB is more comfortable if you’ll run a simulator alongside your code editor)
- A practice drone — something like a DJI Tello (great for absolute beginners, has a simple SDK) or a PX4/ArduPilot-compatible drone if you want to go deeper into open-source flight stacks
- A companion computer if you’re building autonomy features — a Raspberry Pi 4/5 or an NVIDIA Jetson Orin Nano are common starting points for onboard AI work
- A Pixhawk-series flight controller if you’re building a drone from components rather than buying one pre-built
Software setup:
- Install Python 3 and pip
- Install VS Code or PyCharm
- Install MAVSDK-Python (
pip install mavsdk) - Set up Git for version control
- Install a simulator (see Section 10) so you can test before you fly
9. Writing Your First Drone Script
Here’s a minimal script using MAVSDK-Python that connects to a drone (real or simulated), arms it, takes off, hovers, and lands safely. This is the “hello world” of drone programming — nearly every beginner’s first working script looks close to this.
python
import asyncio
from mavsdk import System

async def run():
    drone = System()
    await drone.connect(system_address="udp://:14540")

    print("Waiting for drone to connect...")
    async for state in drone.core.connection_state():
        if state.is_connected:
            print("Drone discovered!")
            break

    print("Arming drone...")
    await drone.action.arm()

    print("Taking off...")
    await drone.action.takeoff()
    await asyncio.sleep(10)

    print("Landing...")
    await drone.action.land()

if __name__ == "__main__":
    asyncio.run(run())
Try this next: once this works against a simulator, modify it to fly a simple square using goto_location() waypoint calls — it’s the natural next step and teaches you the waypoint-navigation concept from Section 4 hands-on.
10. Drone Simulators for Testing Code
Don’t crash your first drone — test in simulation first:
- Gazebo with PX4 SITL — the standard for Linux users, realistic physics, tightly integrated with PX4.
- AirSim by Microsoft — Unreal Engine-based, particularly strong for computer vision and AI training workflows since it can generate realistic camera data.
- DroneBlocks Simulator — great starting point for Tello users and for teaching/learning environments.
- Webots — free, open-source, general-purpose robotics simulator, good if you want simulation skills that transfer beyond just drones.
- QGroundControl (SITL mode) — useful specifically for testing mission planning and ground-control-station workflows.
11. Key Challenges and Safety Tips
- GPS drift — always test GPS-dependent code in open areas away from tall buildings first.
- Battery failure handling — deliberately simulate low-battery conditions in your code paths; don’t assume the happy path.
- Regulations — drone laws vary significantly by country and change often (DGCA rules in India, FAA Part 107 in the US, EASA in the EU). Always check current regulations before flying — don’t rely on any single article, including this one, as your final source.
- Failsafe coding — build explicit emergency land / return-to-home logic; never assume your main control loop won’t fail.
- Pre-flight checklists — treat this as non-negotiable, especially once you’re testing autonomous behavior rather than manual control.
12. Resources and Learning Roadmap
Courses
- Udemy: Drone Programming with Python
- Coursera: Aerial Robotics (University of Pennsylvania)
- PX4 Developer Guide (official documentation)
Books
- Programming Drones: A Beginner’s Guide — John Baichtal
- Mastering ROS for Robotics Programming
Communities
- Dronecode Slack
- PX4 Forums
- Reddit: r/drones, r/uav, r/ArduPilot
GitHub Projects to Study
- DroneKit Python Examples
- MAVSDK sample scripts
- PX4-Autopilot repository (read real flight-stack code, not just tutorials)
13. Frequently Asked Questions
Is drone programming hard to learn if I already know Python? No — if you’re already comfortable with Python, MAVSDK gets you flying a simulated drone within an hour. The steeper learning curve comes later, with control theory (PID tuning) and real-time systems, not the initial scripting.
Do I need to buy a real drone to start learning? No. Every tool in this guide works against a simulator first. Most developers should spend weeks in simulation before ever touching a physical drone.
What’s the difference between DJI SDK and PX4/MAVSDK? DJI SDKs are the right choice if you’re building on DJI’s own hardware and want tight integration with their ecosystem. PX4 + MAVSDK is the open-source path — more flexible, works across many hardware vendors, and is the better choice if you want to understand the flight stack itself rather than just calling an API.
Do I need to learn AI/machine learning to program drones in 2026? Not to get started — the fundamentals in this guide don’t require it. But autonomy-focused drone work is increasingly converging with computer vision, so it’s a natural and valuable next skill once you’re comfortable with the basics.
14. Final Thoughts
Drone programming remains one of the best playgrounds for developers who want to work across software and the physical world — and in 2026, that playground increasingly includes AI-driven autonomy, not just remote-controlled flight paths. Whether you’re aiming to build genuinely autonomous inspection drones or just want to code your drone to follow you around like a pet, the tools to start are more accessible than ever.
Bonus tip: Document your drone-building journey — on FuturisticGeeks or elsewhere — as you go. This niche rewards people who show real, working projects far more than people who only write about theory.

I’ve been exploring for a little bit for any high-quality articles or blog posts on this kind of area . Exploring in Yahoo I at last stumbled upon this website. Reading this information So i’m happy to convey that I have an incredibly good uncanny feeling I discovered just what I needed. I most certainly will make certain to do not forget this website and give it a look on a constant basis.